Learn the key factors behind effective servo motor selection, including torque, speed, duty cycle, environment, and system performance requirements.
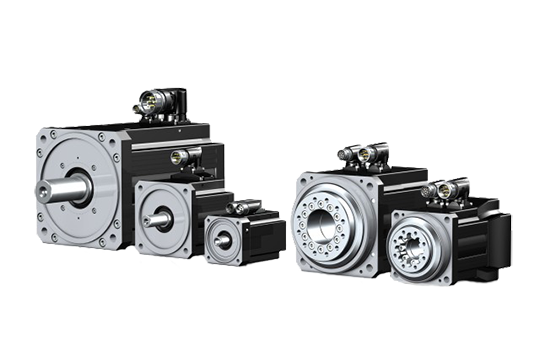
Learn the key factors behind effective servo motor selection, including torque, speed, duty cycle, environment, and system performance requirements.
Explore torque density vs. accuracy in robotic actuators, including key tradeoffs in performance, control, and design for high-precision motion systems.
Learn what gear backlash is, why it occurs, and how it impacts accuracy, noise, and performance in gear systems and motion control applications.
Celebrate Donnie Black’s 15-year career at STOBER as he begins retirement, leaving behind a legacy of problem-solving, dedication, and teamwork.
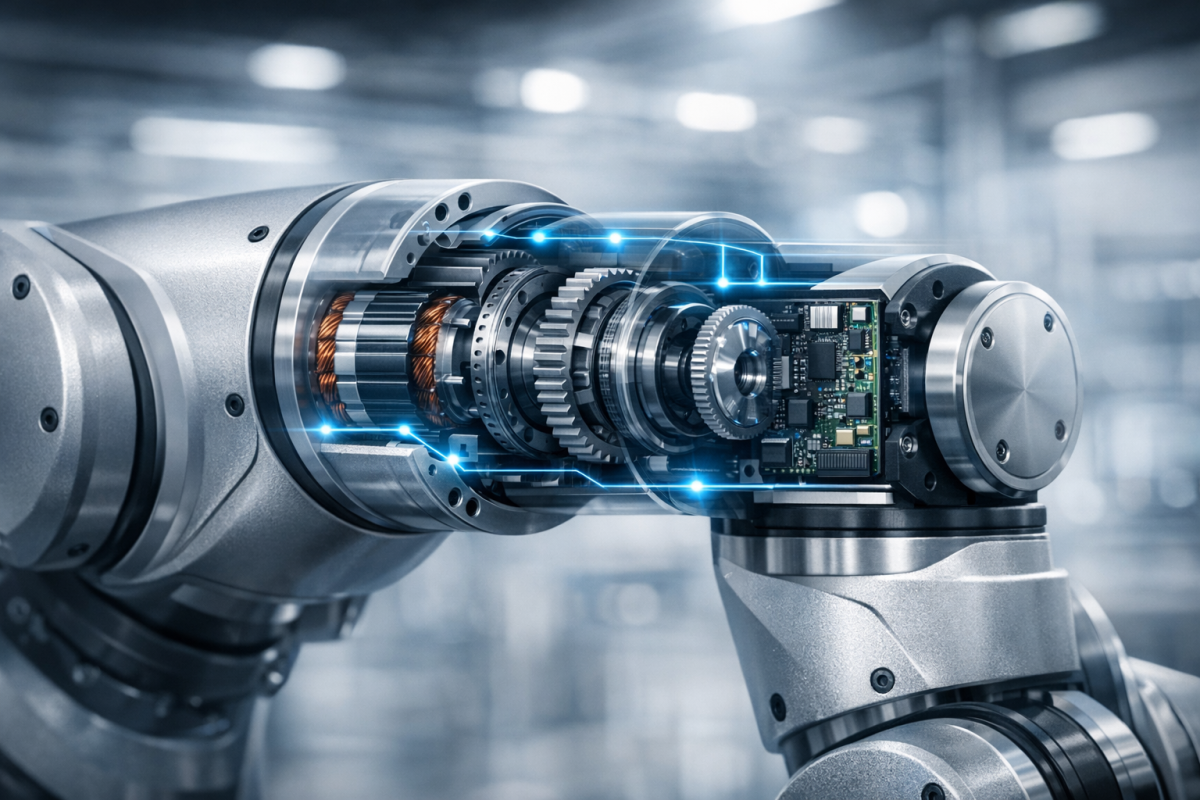
Learn robotic arm joint design, including key components, design challenges, and how precision motion systems impact accuracy and performance.
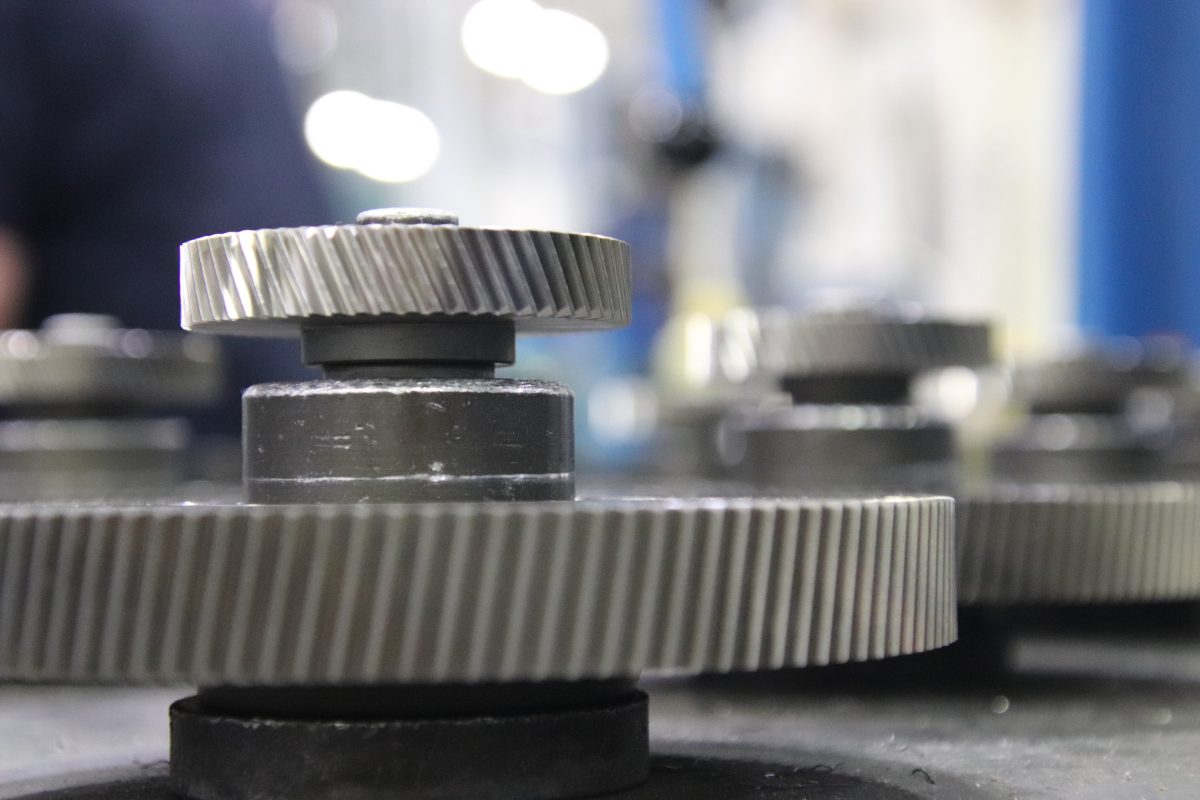
Learn how gearbox efficiency is calculated, what causes power loss, and how to improve gearbox performance through design, lubrication & load optimization.
Celebrate Jeff Frodge’s nearly 11 years at STOBER as he retires on March 31. Read about his impact on the IT team, favorite memories, advice for employees, and plans for the next chapter.
Ideal gearbox selection starts with load data, service factors & environment. Use this sizing checklist to avoid oversizing, cut costs & extend gearbox life.
Learn how to choose gearboxes for automation & robotics—planetary, helical, or helical-bevel—based on load, precision, environment & lifecycle cost.
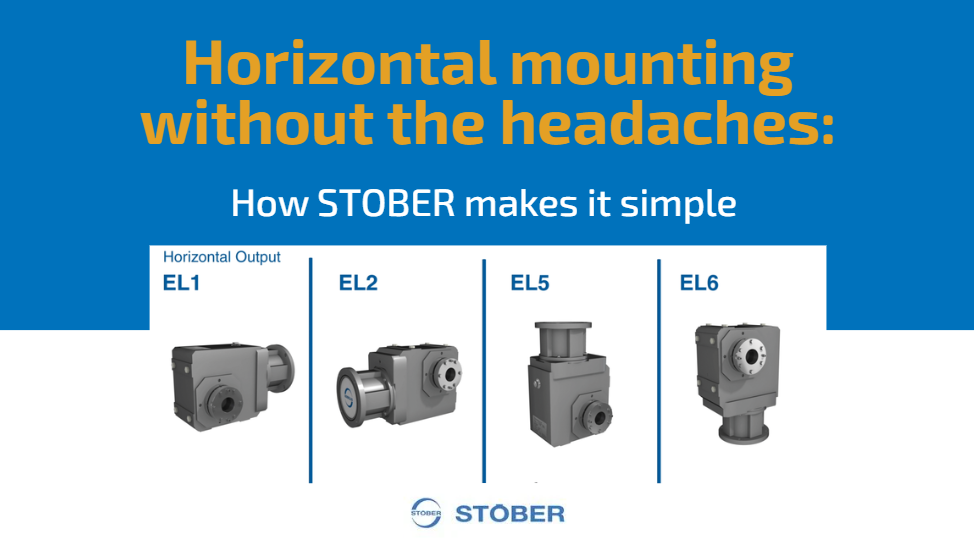
Discover how STOBER eliminates the complexity of horizontal gearbox mounting with flexible, any‑orientation installation, reliable lubrication design, and leak‑proof seals—saving teams time, effort, and costly mistakes.